01PERCEPTION
SEES THE WORKING CONTEXT.
A multi-modal sensing architecture is being developed to interpret people, objects and structured environments in real time.
THE TECHNOLOGY
ARS-1 is being developed as an integrated humanoid system — perception, intelligence, movement and safety engineered together for useful work.
Useful humanoid robotics does not come from a single breakthrough. It comes from the coordination of every layer — from sensing and reasoning to movement, energy and human authority.
A multi-modal sensing architecture is being developed to interpret people, objects and structured environments in real time.
Task understanding, planning and machine state are designed to operate as one supervised decision system.
Whole-body motion is conceived around balance, predictable trajectories and operation in spaces built for people.
Articulated hands and coordinated arm motion target useful interaction with familiar objects, surfaces and equipment.
The electrical architecture is being engineered around practical operating cycles, serviceability and controlled energy use.
Human oversight, defined operating conditions and clear intervention controls are treated as part of the core system.
02 / PERCEPTION & INTELLIGENCE
ARS-1 is being developed to build a live understanding of its surroundings, relate that context to a task and act within clearly defined limits.
MULTI-MODAL INPUTVisual and spatial inputs combined into one operating context.
ENVIRONMENT MODELPeople, objects and navigable space interpreted as a changing scene.
SUPERVISED DECISIONSTask planning designed around human-defined goals and operating boundaries.
Walking is only one part of useful motion. ARS-1 is conceived around coordinated whole-body control: balance, reach, posture and trajectory working together in human environments.
Manipulation is being developed around real objects and real workflows — reaching, grasping, carrying and interacting with the tools already used by people.
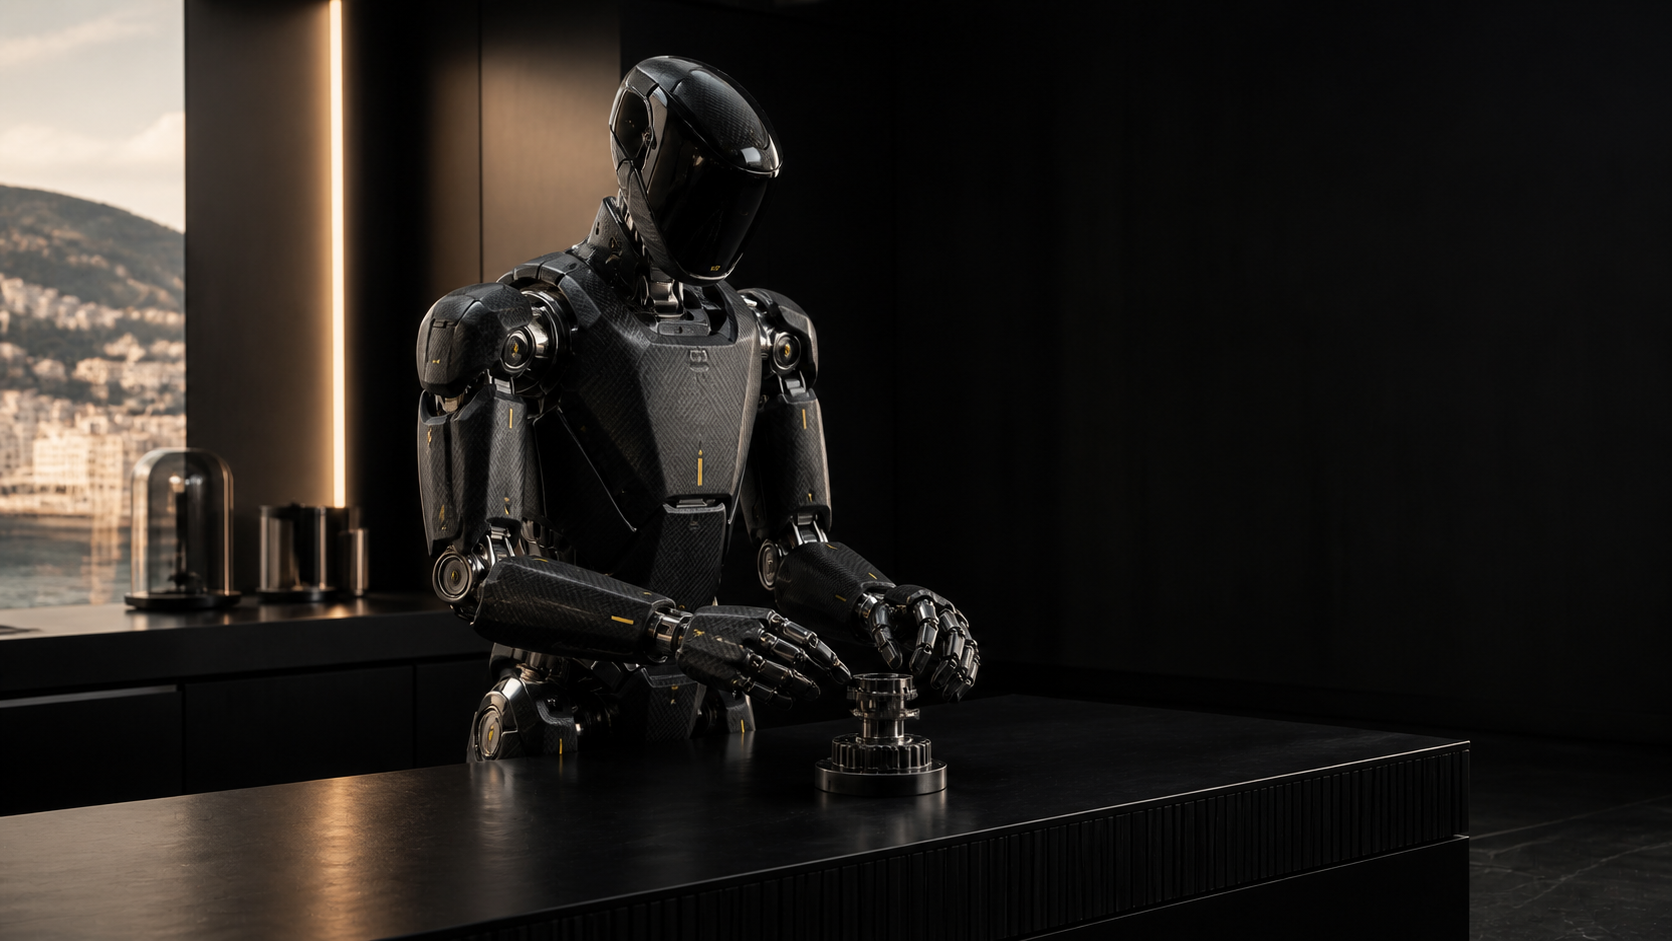
Whole-body positioning designed to bring the hands to the task with stability.
Articulated interaction with varied forms, surfaces and everyday objects.
Two arms, two hands and machine vision working as a single manipulation system.
05 / POWER, SAFETY & VALIDATION
Power management, system awareness and human authority are being developed as operating fundamentals. Performance figures will be released only after the relevant validation programme is complete.
NO UNVALIDATED PERFORMANCE FIGURES ARE PRESENTED AS FINAL SPECIFICATIONS.
ARS-1 / PRIVATE PROGRAMME ACCESS
We are opening selected conversations with deployment partners, technology collaborators and future clients.
Request access ↗